modelAxisType1
Axis model of the r3 joints 1,2,3
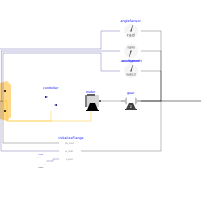
Extends from AxisType2 (Axis model of the r3 joints 4,5,6).
Information
Model of axis 1, 2, 3 of the robot r3. An axis consists of a gearbox with modelled gear elasticity and bearing friction, a model of the electrical motor and a continuous-time cascade controller.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Controller | |||
| Real | kp (from AxisType2) | 10 | Gain of position controller |
| Real | ks (from AxisType2) | 1 | Gain of speed controller |
| SI.Time | Ts (from AxisType2) | 0.01 | Time constant of integrator of speed controller |
| Motor | |||
| Real | k (from AxisType2) | 1.1616 | Gain of motor |
| Real | w (from AxisType2) | 4590 | Time constant of motor |
| Real | D (from AxisType2) | 0.6 | Damping constant of motor |
| SI.Inertia | J (from AxisType2) | 0.0013 | Moment of inertia of motor |
| Gear | |||
| Real | ratio (from AxisType2) | -105 | Gear ratio |
| SI.Torque | Rv0 (from AxisType2) | 0.4 | Viscous friction torque at zero velocity |
| Real | Rv1 (from AxisType2) | (0.13/160) | Viscous friction coefficient |
| Real | peak (from AxisType2) | 1 | Maximum static friction torque is peak*Rv0 (peak >= 1) |
| SI.RotationalSpringConstant | c | 43 | Spring constant |
| SI.RotationalDampingConstant | cd | 0.005 | Damper constant |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange (from AxisType2) | ||
| Modelica.Mechanics.MultiBody.Examples.Systems.RobotR3.Utilities.AxisControlBus | axisControlBus (from AxisType2) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| GearType2 | gear (from AxisType2) | ||
| Motor | motor (from AxisType2) | ||
| Controller | controller (from AxisType2) | ||
| Modelica.Mechanics.Rotational.Sensors.AngleSensor | angleSensor (from AxisType2) | ||
| Modelica.Mechanics.Rotational.Sensors.SpeedSensor | speedSensor (from AxisType2) | ||
| Modelica.Mechanics.Rotational.Sensors.AccSensor | accSensor (from AxisType2) | ||
| Modelica.Mechanics.Rotational.Components.InitializeFlange | initializeFlange (from AxisType2) | ||
| Blocks.Sources.Constant | const (from AxisType2) |