packageForces
Components that exert forces and/or torques between frames
Extends from Modelica.Icons.SourcesPackage (Icon for packages containing sources).
Information
This package contains components that exert forces and torques between two frame connectors, e.g., between two parts.
Content
| Model | Description |
|---|---|
| WorldForce | External force acting at the frame to which this component
is connected and defined by 3 input signals,
that are interpreted as one vector resolved in frame world, frame_b or frame_resolve. |
| WorldTorque | External torque acting at the frame to which this component
is connected and defined by 3 input signals,
that are interpreted as one vector resolved in frame world, frame_b or frame_resolve. |
| WorldForceAndTorque | External force and external torque acting at the frame
to which this component
is connected and defined by 3+3 input signals,
that are interpreted as a force and as a torque vector
resolved in frame world, frame_b or frame_resolve.
|
| Force | Force acting between two frames defined by 3 input signals
resolved in frame world, frame_a, frame_b or in frame_resolve. |
| Torque | Torque acting between two frames defined by 3 input signals
resolved in frame world, frame_a, frame_b or in frame_resolve. |
| ForceAndTorque | Force and torque acting between two frames defined by 3+3 input signals
resolved in frame world, frame_a, frame_b or in frame_resolve. |
| LineForceWithMass | General line force component with an optional point mass
on the connection line. The force law can be defined by a
component of Modelica.Mechanics.Translational |
| LineForceWithTwoMasses | General line force component with two optional point masses
on the connection line. The force law can be defined by a
component of Modelica.Mechanics.Translational |
| Spring | Linear translational spring with optional mass |
| Damper | Linear (velocity dependent) damper |
| SpringDamperParallel | Linear spring and damper in parallel connection |
| SpringDamperSeries | Linear spring and damper in series connection |
Contents
| Name | Description |
|---|---|
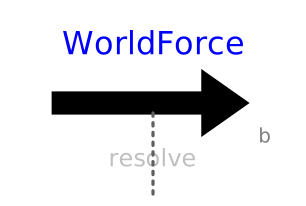 WorldForce | External force acting at frame_b, defined by 3 input signals and resolved in frame world, frame_b or frame_resolve |
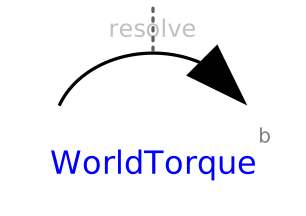 WorldTorque | External torque acting at frame_b, defined by 3 input signals and resolved in frame world, frame_b or frame_resolve |
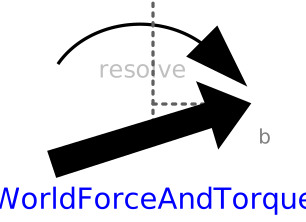 WorldForceAndTorque | External force and torque acting at frame_b, defined by 3+3 input signals and resolved in frame world, frame_b or in frame_resolve |
 Force | Force acting between two frames, defined by 3 input signals and resolved in frame world, frame_a, frame_b or frame_resolve |
 Torque | Torque acting between two frames, defined by 3 input signals and resolved in frame world, frame_a, frame_b or frame_resolve |
 ForceAndTorque | Force and torque acting between two frames, defined by 3+3 input signals and resolved in frame world, frame_a, frame_b or frame_resolve |
 LineForceWithMass | General line force component with an optional point mass on the connection line |
 LineForceWithTwoMasses | General line force component with two optional point masses on the connection line |
 Spring | Linear translational spring with optional mass |
 Damper | Linear (velocity dependent) damper |
 SpringDamperParallel | Linear spring and linear damper in parallel |
 SpringDamperSeries | Linear spring and linear damper in series connection |
 Internal | Internal package, should not be used by user |