modelDamper
Extends from Interfaces.PartialLineForce (Base model for massless line force elements), Modelica.Thermal.HeatTransfer.Interfaces.PartialElementaryConditionalHeatPort (Partial model to include a conditional HeatPort in order to dissipate losses, used for textual modeling, i.e., for elementary models).
Information
Linear damper acting as line force between frame_a and frame_b. A force f is exerted on the origin of frame_b and with opposite sign on the origin of frame_a along the line from the origin of frame_a to the origin of frame_b according to the equation:
f = d*der(s);
where "d" is a parameter, "s" is the distance between the origin of frame_a and the origin of frame_b and der(s) is the time derivative of "s".
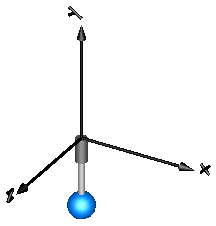
In the following figure a typical animation is shown where a mass is hanging on a damper.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
| SI.TranslationalDampingConstant | d | Damping constant | |
| Boolean | useHeatPort (from PartialElementaryConditionalHeatPort) | false | = true, if heatPort is enabled |
| SI.Temperature | T (from PartialElementaryConditionalHeatPort) | 293.15 | Fixed device temperature if useHeatPort = false |
| Animation › if animation = true | |||
| SI.Distance | length_a | world.defaultForceLength | Length of cylinder at frame_a side |
| Advanced | |||
| SI.Distance | s_small (from LineForceBase) | 1e-10 | Prevent zero-division if distance between frame_a and frame_b is zero |
| Advanced › If enabled, can give wrong results, see MultiBody.UsersGuide.Tutorial.ConnectionOfLineForces | |||
| Boolean | fixedRotationAtFrame_a (from LineForceBase) | false | = true, if rotation frame_a.R is fixed (to directly connect line forces) |
| Boolean | fixedRotationAtFrame_b (from LineForceBase) | false | = true, if rotation frame_b.R is fixed (to directly connect line forces) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialTwoFrames) | Coordinate system a fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_b | frame_b (from PartialTwoFrames) | Coordinate system b fixed to the component with one cut-force and cut-torque | |
| HeatTransfer.Interfaces.HeatPort_a | heatPort (from PartialElementaryConditionalHeatPort) | Optional port to which dissipated losses are transported in form of heat |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Diameter | diameter_a | world.defaultForceWidth | Diameter of cylinder at frame_a side |
| SI.Diameter | diameter_b | 0.6*diameter_a | Diameter of cylinder at frame_b side |
| Types.Color | color_a | {100, 100, 100} | Color at frame_a |
| Types.Color | color_b | {155, 155, 155} | Color at frame_b |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Distance | length (from LineForceBase) | Distance between the origin of frame_a and the origin of frame_b | |
| SI.Position | s (from LineForceBase) | (Guarded) distance between the origin of frame_a and the origin of frame_b (>= s_small)) | |
| SI.Position[3] | r_rel_0 (from LineForceBase) | Position vector from frame_a to frame_b resolved in world frame | |
| Real[3] | e_rel_0 (from LineForceBase) | Unit vector in direction from frame_a to frame_b, resolved in world frame | |
| SI.Position[3] | r_rel_a (from PartialLineForce) | Position vector from origin of frame_a to origin of frame_b, resolved in frame_a | |
| Real[3] | e_a (from PartialLineForce) | Unit vector on the line connecting the origin of frame_a with the origin of frame_b resolved in frame_a (directed from frame_a to frame_b) | |
| SI.Force | f (from PartialLineForce) | Line force acting on frame_a and on frame_b (positive, if acting on frame_b and directed from frame_a to frame_b) | |
| SI.Power | lossPower (from PartialElementaryConditionalHeatPort) | Loss power leaving component via heatPort (> 0, if heat is flowing out of component) | |
| SI.Temperature | TheatPort (from PartialElementaryConditionalHeatPort) | Temperature of heatPort |