modelForceAndTorque
Extends from Modelica.Mechanics.MultiBody.Interfaces.PartialTwoFrames (Base model for components providing two frame connectors + outer world + assert to guarantee that the component is connected).
Information
The 3 signals of the force connector and the 3 signals of the torque connector are interpreted as the x-, y- and z-coordinates of a force and of a torque acting at the frame connector to which frame_b of this component is attached. Via parameter resolveInFrame it is defined, in which frame these coordinates shall be resolved:
| Types.ResolveInFrameAB. | Meaning |
|---|---|
| world | Resolve input force/torque in world frame |
| frame_a | Resolve input force/torque in frame_a |
| frame_b | Resolve input force/torque in frame_b (= default) |
| frame_resolve | Resolve input force/torque in frame_resolve (frame_resolve must be connected) |
If resolveInFrame = ResolveInFrameAB.frame_resolve, the force and torque coordinates are with respect to the frame, that is connected to frame_resolve.
If force={100,0,0}, and for all parameters the default setting is used, then the interpretation is that a force of 100 N is acting along the positive x-axis of frame_b.
Note, a force and torque acts on frame_a in such a way that the force and torque balance between frame_a and frame_b is fulfilled.
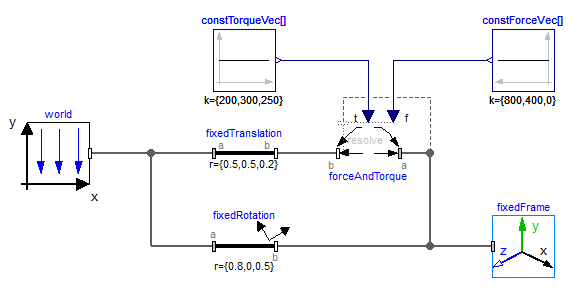
An example how to use this model is given in the following figure:
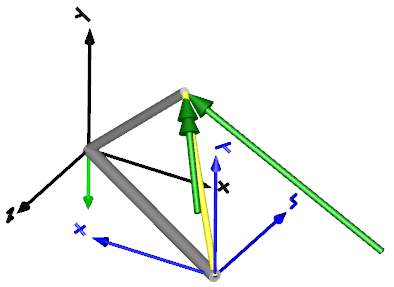
This leads to the following animation (the yellow cylinder characterizes the line between frame_a and frame_b of the ForceAndTorque component, i.e., the force and torque acts with negative sign also on the opposite side of this cylinder, but for clarity this is not shown in the animation):
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameAB | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameAB.frame_b | Frame in which input force and torque are resolved (1: world, 2: frame_a, 3: frame_b, 4: frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialTwoFrames) | Coordinate system a fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_b | frame_b (from PartialTwoFrames) | Coordinate system b fixed to the component with one cut-force and cut-torque | |
| Blocks.Interfaces.RealInput[3] | force | x-, y-, z-coordinates of force resolved in frame defined by resolveInFrame | |
| Blocks.Interfaces.RealInput[3] | torque | x-, y-, z-coordinates of torque resolved in frame defined by resolveInFrame | |
| Interfaces.Frame_resolve | frame_resolve | The input signals are optionally resolved in this frame |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Diameter | connectionLineDiameter | world.defaultArrowDiameter | Diameter of line connecting frame_a and frame_b |
| Types.Color | forceColor | Modelica.Mechanics.MultiBody.Types.Defaults.ForceColor | Color of force arrow |
| Types.Color | torqueColor | Modelica.Mechanics.MultiBody.Types.Defaults.TorqueColor | Color of torque arrow |
| Types.Color | connectionLineColor | Modelica.Mechanics.MultiBody.Types.Defaults.SensorColor | Color of line connecting frame_a and frame_b |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| Internal.BasicForce | basicForce | ||
| Internal.BasicTorque | basicTorque |