modelRollingWheelSet
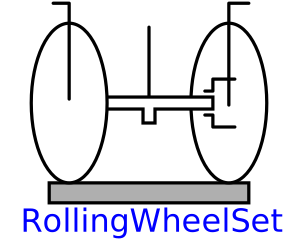
Joint (no mass, no inertia) that describes an ideal rolling wheel set (two ideal rolling wheels connected together by an axis)
Information
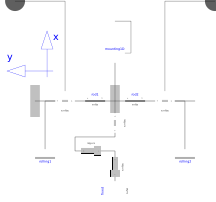
An assembly joint for a wheelset rolling on the x-y plane of the world frame. The frames frame1 and frame2 are connected to rotating wheels; the frameMiddle moves in a plane parallel to the x-y plane of the world and should be connected to the vehicle body.
Note
To work properly, the gravity acceleration vector g of the world must point in the negative z-axis, i.e.
inner Modelica.Mechanics.MultiBody.World world(n={0,0,-1});
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation of wheel set shall be enabled |
| SI.Radius | radius | Radius of one wheel | |
| SI.Distance | track | Distance between the two wheels (= axle track) | |
| StateSelect | stateSelect | StateSelect.default | Priority to use the generalized coordinates as states |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frameMiddle | Frame fixed in middle of axis connecting both wheels (y-axis: along wheel axis, z-Axis: upwards) | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame1 | Frame fixed in center point of left wheel (y-axis: along wheel axis, z-Axis: upwards) | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame2 | Frame fixed in center point of right wheel (y-axis: along wheel axis, z-Axis: upwards) | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | axis1 | 1-dim. rotational flange that drives the joint | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | axis2 | 1-dim. rotational flange that drives the joint | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | support | Support of 1D axes |