modelRollingWheel
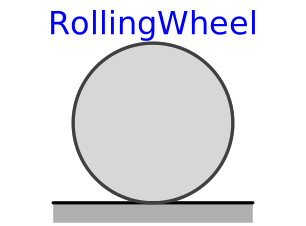
Ideal rolling wheel on flat surface z=0 (5 positional, 3 velocity degrees of freedom)
Information
A wheel rolling on the x-y plane of the world frame including
wheel mass and simple visualization.
The rolling contact is considered being ideal, i.e. there is no
slip between the wheel and the ground.
The wheel can not take off but it can incline toward the ground.
The frame frame_a is placed in the wheel center point and rotates
with the wheel itself. Therefore, a
rotational joint
with rotation axis n={0,1,0} should be used to
connect the wheel to a carrier.
Note
To work properly, the gravity acceleration vector g of the world must point in the negative z-axis, i.e.
inner Modelica.Mechanics.MultiBody.World world(n={0,0,-1});
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation of wheel shall be enabled |
| SI.Radius | radius | Radius of wheel | |
| SI.Mass | m | Mass of wheel | |
| SI.Inertia | I_axis | Inertia along the wheel axis | |
| SI.Inertia | I_long | Inertia perpendicular to the wheel axis | |
| StateSelect | stateSelect | StateSelect.always | Priority to use generalized coordinates as states |
| Animation › if animation = true | |||
| SI.Distance | width | 0.035 | Width of wheel |
| Real | hollowFraction | 0.8 | For ring-like visualization: wheel radius / inner hole radius; i.e. 1.0: completely hollow, 0.0: full disc |
| Types.Color | color | {30, 30, 30} | Color of wheel |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a | Frame fixed in wheel center point (y-axis: along wheel axis, z-axis: upwards) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Position | x | x-coordinate of wheel axis | |
| SI.Position | y | y-coordinate of wheel axis | |
| SI.Angle[3] | angles | Angles to rotate world-frame in to frame_a around z-, y-, x-axis | |
| SI.AngularVelocity[3] | der_angles | Derivative of angles | |
| Modelica.Mechanics.MultiBody.Parts.Body | body | ||
| Modelica.Mechanics.MultiBody.Joints.RollingWheel | rollingWheel | ||
| Modelica.Mechanics.MultiBody.Visualizers.FixedShape | fixedShape |