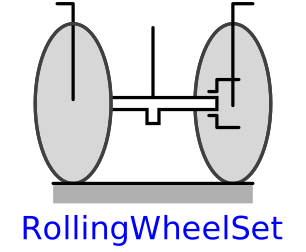
modelRollingWheelSet
Ideal rolling wheel set consisting of two ideal rolling wheels connected together by an axis
Information
Two wheels are connected by an axis and can rotate around this axis. The wheels are rolling on the x-y plane of the world frame. The coordinate system attached to the center of the wheel axis (frameMiddle) is constrained so that it is always parallel to the x-y plane. If all generalized coordinates are zero, frameMiddle is parallel to the world frame.
Note
To work properly, the gravity acceleration vector g of the world must point in the negative z-axis, i.e.
inner Modelica.Mechanics.MultiBody.World world(n={0,0,-1});
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation of wheel set shall be enabled |
| SI.Radius | R_wheel | Radius of one wheel | |
| SI.Mass | m_wheel | Mass of one wheel | |
| SI.Inertia | I_wheelAxis | Inertia along one wheel axis | |
| SI.Inertia | I_wheelLong | Inertia perpendicular to one wheel axis | |
| SI.Distance | track | Distance between the two wheels (= axle track) | |
| StateSelect | stateSelect | StateSelect.always | Priority to use the generalized coordinates as states |
| Animation › if animation = true | |||
| SI.Distance | width_wheel | 0.01 | Width of one wheel |
| Real | hollowFraction | 0.8 | For ring-like wheel visualization: wheel radius / inner hole radius; i.e. 1.0: completely hollow, 0.0: full disc |
| Types.Color | color | {30, 30, 30} | Color of wheels |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frameMiddle | Frame fixed in middle of axis connecting both wheels (y-axis: along wheel axis, z-axis: upwards) | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame1 | Frame fixed in center point of left wheel (y-axis: along wheel axis, z-axis: upwards) | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame2 | Frame fixed in center point of right wheel (y-axis: along wheel axis, z-axis: upwards) | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | axis1 | 1-dim. rotational flange that drives the left wheel | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | axis2 | 1-dim. rotational flange that drives the right wheel | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | support | Support of 1D axes |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Position | x | x coordinate of center between wheels | |
| SI.Position | y | y coordinate of center between wheels | |
| SI.Angle | phi | Orientation angle of wheel axis along z-axis | |
| SI.Angle | theta1 | Angle of wheel 1 | |
| SI.Angle | theta2 | Angle of wheel 2 | |
| SI.AngularVelocity | der_theta1 | Derivative of theta 1 | |
| SI.AngularVelocity | der_theta2 | Derivative of theta 2 | |
| Modelica.Mechanics.MultiBody.Parts.Body | body2 | ||
| Modelica.Mechanics.MultiBody.Visualizers.FixedShape | shape2 | ||
| Modelica.Mechanics.MultiBody.Parts.Body | body1 | ||
| Modelica.Mechanics.MultiBody.Visualizers.FixedShape | shape1 | ||
| Modelica.Mechanics.MultiBody.Joints.RollingWheelSet | wheelSetJoint |