modelCutForce
Extends from Modelica.Mechanics.MultiBody.Sensors.Internal.PartialCutForceSensor (Base class to measure cut force and/or torque between two frames, defined by components).
Information
The cut-force acting between the two frames to which this model is connected, is determined and provided at the output signal connector force (= frame_a.f). If parameter positiveSign = false, the negative cut-force is provided (= frame_b.f).
Via parameter resolveInFrame it is defined, in which frame the force vector is resolved:
| resolveInFrame = Types.ResolveInFrameA. | Meaning |
|---|---|
| world | Resolve vector in world frame |
| frame_a | Resolve vector in frame_a |
| frame_resolve | Resolve vector in frame_resolve |
If resolveInFrame = Types.ResolveInFrameAB.frame_resolve, the conditional connector "frame_resolve" is enabled and output force is resolved in the frame, to which frame_resolve is connected. Note, if this connector is enabled, it must be connected.
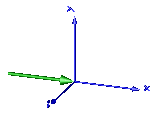
In the following figure the animation of a CutForce sensor is shown. The dark blue coordinate system is frame_b, and the green arrow is the cut force acting at frame_b and with negative sign at frame_a.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled (show arrow) |
| Boolean | positiveSign | true | = true, if force with positive sign is returned (= frame_a.f), otherwise with negative sign (= frame_b.f) |
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame (from PartialCutForceSensor) | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector(s) is/are resolved (world, frame_a, or frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealOutput[3] | force | Cut force resolved in frame defined by resolveInFrame | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a (from PartialCutForceSensor) | Coordinate system a | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame_b (from PartialCutForceSensor) | Coordinate system b | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_resolve | frame_resolve (from PartialCutForceSensor) | Output vectors are optionally resolved in this frame (cut-force/-torque are set to zero) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Types.Color | forceColor | Modelica.Mechanics.MultiBody.Types.Defaults.ForceColor | Color of force arrow |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |