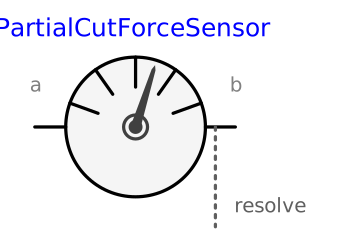
modelPartialCutForceSensor
Base class to measure cut force and/or torque between two frames, defined by components
Extends from Modelica.Icons.RoundSensor (Icon representing a round measurement device).
Information
This is a base class for 3-dim. mechanical components with two frames and one output port in order to measure the cut-force and/or cut-torque acting between the two frames and to provide the measured signals as output for further processing with the blocks of package Modelica.Blocks.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector(s) is/are resolved (world, frame_a, or frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a | Coordinate system a | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame_b | Coordinate system b | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_resolve | frame_resolve | Output vectors are optionally resolved in this frame (cut-force/-torque are set to zero) |