
modelJointUSP
One kinematic loop with four bars (using JointUSP joint)
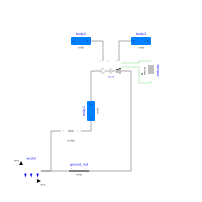
Extends from Modelica.Icons.Example (Icon for runnable examples).
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Angle | revolute_phi | angle of revolute joint j1 | |
| SI.Position | prismatic_s | distance of prismatic joint j2 | |
| SI.AngularVelocity | revolute_w | axis speed of revolute joint j1 | |
| SI.Velocity | prismatic_v | axis velocity of prismatic joint j2 | |
| MultiBody.World | world | ||
| MultiBody.Joints.Revolute | revolute | ||
| MultiBody.Parts.BodyCylinder | body1 | ||
| MultiBody.Parts.BodyCylinder | body3 | ||
| MultiBody.Parts.FixedTranslation | ground_rod | ||
| MultiBody.Joints.Assemblies.JointUSP | jointUSP | ||
| MultiBody.Parts.BodyCylinder | body2 | ||
| Modelica.Mechanics.Translational.Components.Damper | damper |