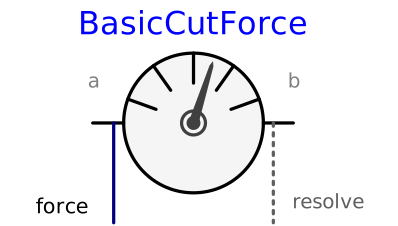
modelBasicCutForce
Measure cut force vector (frame_resolve must be connected)
Extends from Internal.PartialCutForceBaseSensor (Base model to measure the cut force and/or torque between two frames, defined by equations (frame_resolve must be connected exactly once)).
Information
This sensor outputs cut-force between the two connecting frames,
whereby the output signal force = {frame_a.fx, frame_a.fy}.
If parameter positiveSign = false, the negative
cut-force is provided.
The cut-force is resolved in frame specified by the parameter
resolveInFrame
The connector frame_resolve is always present and must,
therefore, be always connected from outside.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame (from PartialCutForceBaseSensor) | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector is resolved (1: world, 2: frame_a, 3: frame_resolve) |
| Boolean | positiveSign | true | = true, if force with positive sign is returned (= frame_a.f), otherwise with negative sign (= frame_b.f) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialCutForceBaseSensor) | Coordinate system a | |
| Interfaces.Frame_b | frame_b (from PartialCutForceBaseSensor) | Coordinate system b | |
| Interfaces.Frame_resolve | frame_resolve (from PartialCutForceBaseSensor) | The output vector is optionally resolved in this frame (cut-force/-torque are set to zero) | |
| Modelica.Blocks.Interfaces.RealOutput[2] | force | Cut force resolved in frame defined by resolveInFrame |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control