modelPartialCutForceBaseSensor
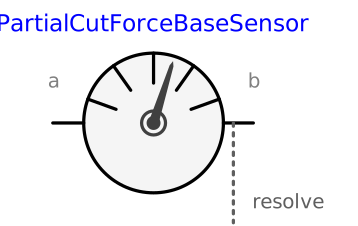
Base model to measure the cut force and/or torque between two frames, defined by equations (frame_resolve must be connected exactly once)
Extends from Modelica.Icons.RoundSensor (Icon representing a round measurement device).
Information
This is a base class for 3-dim. mechanical components with two frames and one output port in order to measure the cut-force and/or cut-torque acting between the two frames and to provide the measured signals as output for further processing with the blocks of package Modelica.Blocks.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector is resolved (1: world, 2: frame_a, 3: frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a | Coordinate system a | |
| Interfaces.Frame_b | frame_b | Coordinate system b | |
| Interfaces.Frame_resolve | frame_resolve | The output vector is optionally resolved in this frame (cut-force/-torque are set to zero) |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control