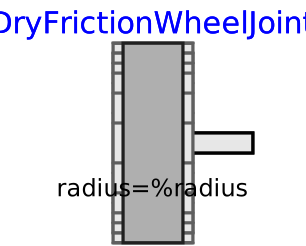
modelDryFrictionWheelJoint
Extends from PlanarMechanics.VehicleComponents.Wheels.BaseClasses.WheelBase (Enhanced partial base class containing wheel interfaces and icon).
Information
The ideal wheel joint models the behavior of a wheel rolling on a x,y-plane whose contact patch has dry-friction characteristics. This is an approximation for stiff wheels without a tire.
The force depends with dry-friction characteristics on the slip velocity. The slip velocity is split into two components:
- the lateral velocity
- the longitudinal velocity minus the rolling velocity times the radius.
The radius of the wheel can be specified by the parameter radius. The driving direction (for phi = 0) can be specified by the parameter r. The normal load is set by N.
The wheel contains a 2D connector frame_a for the steering on the plane. The rolling motion of the wheel can be actuated by the 1D connector flange_a.
For examples of usage see the local Examples package.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useHeatPort (from PartialElementaryConditionalHeatPortWithoutT) | false | = true, if heatPort is enabled |
| SI.Length | radius (from WheelBase) | Wheel radius | |
| SI.Length[2] | r | Driving direction of the wheel at angle phi = 0 | |
| SI.Force | N | Normal force | |
| SI.Velocity | vAdhesion | Adhesion velocity | |
| SI.Velocity | vSlide | Sliding velocity | |
| Real | mu_A | Friction coefficient at adhesion | |
| Real | mu_S | Friction coefficient at sliding | |
| SI.Length | l | Modelica.Math.Vectors.length(r) | Length of r |
| Real[2] | e | Modelica.Math.Vectors.normalizeWithAssert(r) | Unit vector in direction of r |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use acceleration as states |
| Animation | |||
| Boolean | animate | true | = true, if animation shall be enabled |
| Animation › if animation = true | |||
| SI.Length | zPosition | planarWorld.defaultZPosition | Position z of the body |
| SI.Length | diameter | 0.1 | Deprecated: Diameter of the rims |
| SI.Length | width | 0.6*radius | Wheel width |
| SI.Length | rRim | 0.9*radius | Rim radius |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| HeatTransfer.Interfaces.HeatPort_a | heatPort (from PartialElementaryConditionalHeatPortWithoutT) | Optional port to which dissipated losses are transported in form of heat | |
| Interfaces.Frame_a | frame_a (from WheelInterfaces) | ||
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | flange_a (from WheelInterfaces) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Power | lossPower (from PartialElementaryConditionalHeatPortWithoutT) | Loss power leaving component via heatPort (> 0, if heat is flowing out of component) | |
| PlanarWorld | planarWorld | planar world model | |
| Real[2] | e0 | Unit vector in direction of r resolved w.r.t. inertial frame | |
| Real[2,2] | R | Rotation matrix | |
| SI.Angle | phi_roll | Roll angle of the wheel | |
| SI.AngularVelocity | w_roll | Roll velocity of wheel | |
| SI.Velocity[2] | v | Velocity | |
| SI.Velocity | v_lat | Driving in lateral direction | |
| SI.Velocity | v_long | Velocity in longitudinal direction | |
| SI.Velocity | v_slip_long | Slip velocity in longitudinal direction | |
| SI.Velocity | v_slip_lat | Slip velocity in lateral direction | |
| SI.Velocity | v_slip | Slip velocity | |
| SI.Force | f | Longitudinal force | |
| SI.Force | f_lat | Longitudinal force | |
| SI.Force | f_long | Longitudinal force | |
| MB.Types.Color | color | PlanarMechanics.Types.Defaults.WheelColor | Color of shape |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control