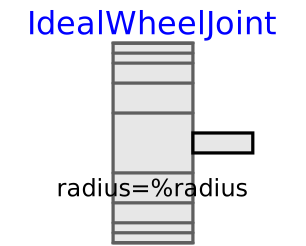
modelIdealWheelJoint
Extends from PlanarMechanics.VehicleComponents.Wheels.BaseClasses.WheelBase (Enhanced partial base class containing wheel interfaces and icon).
Information
The ideal wheel joint enforces the constraints of ideal rolling on the x,y-plane.
The constraint is that the velocity of the virtual point of contact shall be zero. This constrains is split into two components:
- no lateral velocity
- the longitudinal velocity has to equal the rolling velocity times the radius.
The radius of the wheel can be specified by the parameter radius. The driving direction (for phi = 0) can be specified by the parameter r.
The wheel contains a 2D frame connector for the steering on the plane. The rolling motion of the wheel can be actuated by the 1D flange connector.
For examples of usage see the local Examples package.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useHeatPort (from PartialElementaryConditionalHeatPortWithoutT) | false | = true, if heatPort is enabled |
| SI.Length | radius (from WheelBase) | Wheel radius | |
| SI.Length[2] | r | Driving direction of the wheel at angle phi = 0 | |
| SI.Length | l | Modelica.Math.Vectors.length(r) | Length of r |
| Real[2] | e | Modelica.Math.Vectors.normalizeWithAssert(r) | Unit vector in direction of r |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use acceleration as states |
| Animation | |||
| Boolean | animate | true | = true, if animation shall be enabled |
| Animation › if animation = true | |||
| SI.Length | zPosition | planarWorld.defaultZPosition | Position z of the body |
| SI.Length | diameter | 0.1 | Deprecated: Diameter of the rims |
| SI.Length | width | 0.6*radius | Wheel width |
| SI.Length | rRim | 0.9*radius | Rim radius |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| HeatTransfer.Interfaces.HeatPort_a | heatPort (from PartialElementaryConditionalHeatPortWithoutT) | Optional port to which dissipated losses are transported in form of heat | |
| Interfaces.Frame_a | frame_a (from WheelInterfaces) | ||
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | flange_a (from WheelInterfaces) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Power | lossPower (from PartialElementaryConditionalHeatPortWithoutT) | Loss power leaving component via heatPort (> 0, if heat is flowing out of component) | |
| PlanarWorld | planarWorld | planar world model | |
| Real[2] | e0 | Unit vector in direction of r resolved w.r.t. inertial frame | |
| Real[2,2] | R | Rotation matrix | |
| SI.Angle | phi_roll | Roll angle of the wheel | |
| SI.AngularVelocity | w_roll | Roll velocity of wheel | |
| SI.Velocity[2] | v | Velocity | |
| SI.Velocity | v_long | Driving velocity in (longitudinal) driving direction | |
| SI.Acceleration | a | Acceleration of driving velocity | |
| SI.Force | f_long | Longitudinal force | |
| MB.Types.Color | color | PlanarMechanics.Types.Defaults.WheelColor | Color of shape |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control