modelExternalAirStation
Extends from PartialAirStation.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | reverse_direction (from PartialAirStation) | false | |
| Real | orientation_factor (from PartialAirStation) | if reverse_direction then -1.0 else 1.0 | |
| Real | c (from PartialAirStation) | 0.121 | Chord length |
| Real | b (from PartialAirStation) | c/2 | Semi-chord length |
| Real | a (from PartialAirStation) | 0.0 | Distance from to blade rotation position to mid-chord, measured in semi-chords |
| Modelica.SIunits.Length | delta_r (from PartialAirStation) | 1.0 | Effective length used to lump field forces/torques |
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveSensorInFrame (from PartialAirStation) | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_resolve | Frame in which sensor data (r, v, angles) is resolved (1: world, 2: frame_b, 3: frame_resolve) |
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameB | resolveLoadInFrame (from PartialAirStation) | Modelica.Mechanics.MultiBody.Types.ResolveInFrameB.frame_resolve | Frame in which force data (force, torque) is resolved (1: world, 2: frame_b, 3: frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_b | frame_b (from PartialOneFrame_b) | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_resolve | relativeFrame_resolve (from PartialAirStation) | The sensor signals are optionally resolved in this frame |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Force | f (from PartialAirStation) | ||
| SI.Torque | t (from PartialAirStation) | ||
| SI.Position | r (from PartialAirStation) | ||
| SI.Velocity | v_rotor (from PartialAirStation) | ||
| SI.Angle | angles (from PartialAirStation) | ||
| SI.Angle | theta (from PartialAirStation) | ||
| Real | thetadot (from PartialAirStation) | ||
| Real | delta_Fx (from PartialAirStation) | ||
| Real | delta_Fz (from PartialAirStation) | ||
| Real | delta_Fy (from PartialAirStation) | ||
| Real | delta_Tx (from PartialAirStation) | ||
| Real | delta_Ty (from PartialAirStation) | ||
| Real | delta_Tz (from PartialAirStation) | ||
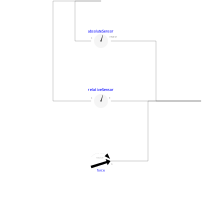
| Modelica.Mechanics.MultiBody.Sensors.AbsoluteSensor | absoluteSensor (from PartialAirStation) | ||
| Modelica.Mechanics.MultiBody.Forces.WorldForceAndTorque | force (from PartialAirStation) | ||
| Modelica.Mechanics.MultiBody.Sensors.RelativeSensor | relativeSensor (from PartialAirStation) |