modelRRMotor2Control
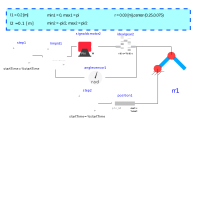
Extends from Modelica.Icons.Example (Icon for runnable examples), Servomechanisms.Examples.RRServomechanism.Data (RR Servomechanism Data).
Information
General
With this example the position control of the motor can be verified.
The weigth of the links when the centroid is outside the motor or transmition axis generates disturbances
that sometimes reduce the precision of the control loop.
If those disturbances are relatively small the proportional control P can be used otherwise a PI or PID control is preferred.
Implementation
The effect of disturbances for proportional position control are. MSL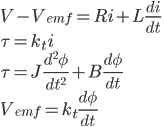
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | l1 (from Data) | 0.2 | |
| Real | w1 (from Data) | 0.02 | |
| Real | h1 (from Data) | 0.005 | |
| Real | d1 (from Data) | 400 | |
| Real | min1 (from Data) | 0 | |
| Real | max1 (from Data) | pi/2 | |
| Real | l2 (from Data) | 0.1 | |
| Real | w2 (from Data) | 0.02 | |
| Real | h2 (from Data) | 0.005 | |
| Real | d2 (from Data) | 400 | |
| Real | min2 (from Data) | -pi/2 | |
| Real | max2 (from Data) | pi/2 | |
| Real | r (from Data) | 0.03 | |
| Real | xc (from Data) | 0.25 | |
| Real | yc (from Data) | 0.075 | |
| Real | ratio1 (from Data) | 10 | |
| Real | ratio2 (from Data) | 5 | |
| Real | period (from Data) | 8 | |
| Real | R (from Data) | 0.101 | |
| Real | L (from Data) | 0.0000266 | |
| Real | k (from Data) | 0.0115 | |
| Real | J (from Data) | 0.0000119 | |
| Real | Voltage (from Data) | 12 | |
| Real | kp2 (from Data) | 4.423 | |
| Real | kp1 (from Data) | 7.1543 |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Servomechanisms.Electrical.SignalDCMotor | signaldcmotor2 | ||
| Modelica.Mechanics.Rotational.Components.IdealGear | idealgear2 | ||
| Modelica.Blocks.Sources.Step | step1 | ||
| Modelica.Blocks.Continuous.LimPID | limpid1 | ||
| Modelica.Mechanics.Rotational.Sources.Position | position1 | ||
| Modelica.Mechanics.Rotational.Sensors.AngleSensor | anglesensor1 | ||
| Modelica.Blocks.Sources.Step | step2 | ||
| Servomechanisms.Mechanism.RR | rr1 |