modelRRWorkspace
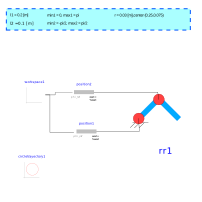
Extends from Modelica.Icons.Example (Icon for runnable examples), Servomechanisms.Examples.RRServomechanism.Data (RR Servomechanism Data).
Information
General
The purpose of this model is to determine de workspace and possible trayectory of the mechanism. The parameters used are located in the record. This parameters are used as the parameters of each component as needed.
Implementation
The Workspace2d generates references values between the ranges of the joints feasible motion. This values are then introduced into Angular position sources (from MSL ) and then connected to the RR component.
Notes
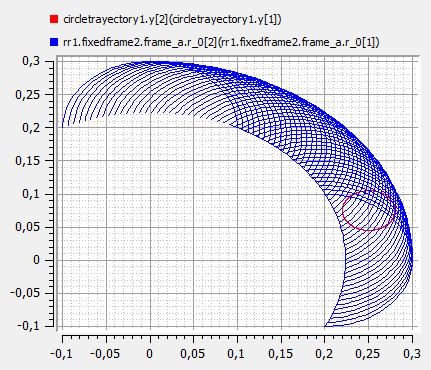
- The block circletrayectory is utilized to verify that the trayectory is within the workspace.
- Note that the parameter exact in each position source is true to avoid the minimal frequency.
- Both, the workspace and circle trayectory are completed in 1 sec.
Results
The simulation results in parametric plot are:
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | l1 (from Data) | 0.2 | |
| Real | w1 (from Data) | 0.02 | |
| Real | h1 (from Data) | 0.005 | |
| Real | d1 (from Data) | 400 | |
| Real | min1 (from Data) | 0 | |
| Real | max1 (from Data) | pi/2 | |
| Real | l2 (from Data) | 0.1 | |
| Real | w2 (from Data) | 0.02 | |
| Real | h2 (from Data) | 0.005 | |
| Real | d2 (from Data) | 400 | |
| Real | min2 (from Data) | -pi/2 | |
| Real | max2 (from Data) | pi/2 | |
| Real | r (from Data) | 0.03 | |
| Real | xc (from Data) | 0.25 | |
| Real | yc (from Data) | 0.075 | |
| Real | ratio1 (from Data) | 10 | |
| Real | ratio2 (from Data) | 5 | |
| Real | period (from Data) | 8 | |
| Real | R (from Data) | 0.101 | |
| Real | L (from Data) | 0.0000266 | |
| Real | k (from Data) | 0.0115 | |
| Real | J (from Data) | 0.0000119 | |
| Real | Voltage (from Data) | 12 | |
| Real | kp2 (from Data) | 4.423 | |
| Real | kp1 (from Data) | 7.1543 |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Sources.Position | position1 | ||
| Modelica.Mechanics.Rotational.Sources.Position | position2 | ||
| Servomechanisms.Mechanism.Workspace2d | workspace1 | ||
| Servomechanisms.Mechanism.RR | rr1 | ||
| Servomechanisms.Control.CircleTrayectory | circletrayectory1 |