modelSimpleControlledDrive_original

Controlled drive train
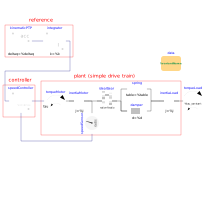
Extends from Modelica.Icons.Example (Icon for runnable examples), Credibility.Examples.SimpleControlledDriveNonlinear.PartialDrive (Not calibrated drive model with nonlinear compliance).

Information

This is a simple nonlinear drive train controlled by a PI controller, based on Modelica.Blocks.Examples.PID_Controller.

It serves as an example for the use of the Credibility library.

Detailed information can be found in [Otter2022]).

Parameters

TypeNameDefaultDescription
PartialDatadata (from PartialDrive)Data of the drive train, including credibility information
Modelica.Units.SI.AngledriveAngle1.570796326794897Reference distance to move

Components

TypeNameDefaultDescription
Modelica.Mechanics.Rotational.Components.InertiainertiaMotor (from PartialDrive)J from datasheet; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Sources.TorquetorqueMotor (from PartialDrive)
Credibility.Examples.SimpleControlledDriveNonlinear.Utilities.SpringNonLinearspring (from PartialDrive)table from datasheet; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Components.Damperdamper (from PartialDrive)d to be calibrated; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Components.InertiainertiaLoad (from PartialDrive)Guess value, with defined uncertainty; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Sensors.SpeedSensorspeedSensor (from PartialDrive)
Modelica.Mechanics.Rotational.Components.IdealGearidealGear (from PartialDrive)
Modelica.Blocks.Continuous.LimPIDspeedControllerk, Ti, Ni: defined from control development, to be tested on control robustness ; yMax, yMin: from system spec; Init defined by optimization scenario spec
Modelica.Blocks.Continuous.Integratorintegrator
Modelica.Blocks.Sources.KinematicPTPkinematicPTP
Modelica.Mechanics.Rotational.Sources.ConstantTorquetorqueLoad