modelThreeArms_P1_IdealActVel
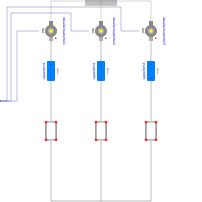
Extends from DeltaRobot.Icons.ThreeArms_IdealActVel (Icon for 'ThreeArms_IdealActVel' model), PartialThreeArms (Partial model of the three arms of a Delta robot).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Arms | |||
| ArmParameters[3] | armParameters (from PartialThreeArms) | gp.armParameters | Parameters of the arms |
| Actuators | |||
| ActuatorParameters[3] | actuatorParameters (from PartialThreeArms) | gp.actuatorParameters | Parameters of the rotary actuators |
| Reducers | |||
| ReducerParameters[3] | reducerParameters (from PartialThreeArms) | gp.reducerParameters | Parameters of the gearbox reducers |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a[3] | frame_base (from PartialThreeArms) | Frames for connection with the base's joints | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b[3] | frame_platform (from PartialThreeArms) | Frames for connection with the platform's joints | |
| Modelica.Blocks.Interfaces.RealInput[3] | angleVelRef |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| DeltaRobot.Components.GlobalParameters | gp (from PartialThreeArms) | ||
| SI.Torque[3] | motorTorqueDIS (from PartialThreeArms) | Display torque applied by motors | |
| SI.AngularVelocity[3] | motorVelocityDIS (from PartialThreeArms) | Angular velocity of morots | |
| Modelica.Mechanics.MultiBody.Parts.BodyCylinder | upperArm1 (from PartialThreeArms) | ||
| Modelica.Mechanics.MultiBody.Parts.BodyCylinder | upperArm2 (from PartialThreeArms) | ||
| Modelica.Mechanics.MultiBody.Parts.BodyCylinder | upperArm3 (from PartialThreeArms) | ||
| DeltaRobot.Components.IdealActuatorVel | idealActuatorVel1 | ||
| DeltaRobot.Components.IdealActuatorVel | idealActuatorVel2 | ||
| DeltaRobot.Components.IdealActuatorVel | idealActuatorVel3 | ||
| DeltaRobot.Components.Parallelogram1 | parallelogram1_1 | ||
| DeltaRobot.Components.Parallelogram1 | parallelogram1_2 | ||
| DeltaRobot.Components.Parallelogram1 | parallelogram1_3 |