
modelPlanarFourbar
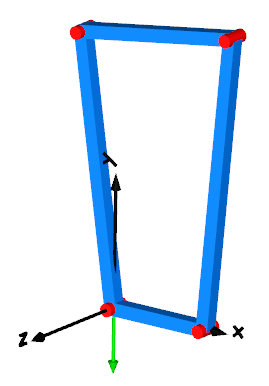
Planar four bars mechanism with one kinematic loop (with RevolutePlanarLoopConstraint joint)
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
A planar four link mechanism demonstrating possible usage of the RevolutePlanarLoopConstraint. In this planar example, all the revolute joints rotate about axes perpendicular to the x-y plane, i.e. they all are parallel to each other. To enable a unique numerical solution in such a case, one RevolutePlanarLoopConstraint has to be introduced instead of the common revolute joint.
Another option is to use the assembly joint Joints.Assemblies.JointRRR instead of a part of the mechanism, as demonstrated in the example PlanarLoops_analytic.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Joints.Revolute | revolute1 | ||
| Joints.Revolute | revolute2 | ||
| Joints.Revolute | revolute3 | ||
| Joints.RevolutePlanarLoopConstraint | revolute4cut | ||
| Parts.BodyBox | body1 | ||
| Parts.BodyBox | body2 | ||
| Parts.BodyBox | body3 | ||
| Parts.BodyBox | body4 | ||
| Modelica.Mechanics.MultiBody.World | world | ||
| Rotational.Components.Damper | damper | ||
| Sensors.RelativeSensor | sensorJoint4 |