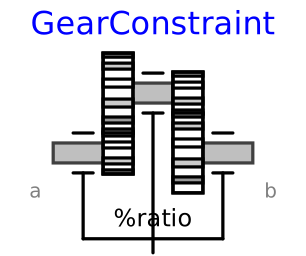
modelGearConstraint
Ideal 3-dim. gearbox (arbitrary shaft directions)
Extends from Modelica.Mechanics.MultiBody.Interfaces.PartialTwoFrames (Base model for components providing two frame connectors + outer world + assert to guarantee that the component is connected).
Information
This ideal massless joint provides a gear constraint between
frames frame_a and frame_b. The axes of rotation
of frame_a and frame_b may be arbitrary.
Reference
Schweiger, Christian ;
Otter, Martin:
Modelling
3D Mechanical Effects of 1-dim. Powertrains. In: Proceedings of the 3rd International
Modelica Conference. Linköping : The Modelica Association and Linköping University,
November 3-4, 2003, pp. 149-158
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | ratio | Gear speed ratio | |
| Modelica.Mechanics.MultiBody.Types.Axis | n_a | {1, 0, 0} | Axis of rotation of shaft a (same coordinates in frame_a, frame_b, bearing) |
| Modelica.Mechanics.MultiBody.Types.Axis | n_b | {1, 0, 0} | Axis of rotation of shaft b (same coordinates in frame_a, frame_b, bearing) |
| SI.Position[3] | r_a | {0, 0, 0} | Vector from frame bearing to frame_a resolved in bearing |
| SI.Position[3] | r_b | {0, 0, 0} | Vector from frame bearing to frame_b resolved in bearing |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use joint coordinates (phi_a, phi_b, w_a, w_b) as states |
| Boolean | checkTotalPower | false | = true, if total power flowing into this component shall be determined (must be zero) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialTwoFrames) | Coordinate system a fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_b | frame_b (from PartialTwoFrames) | Coordinate system b fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_a | bearing | Coordinate system fixed in the bearing |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Angle | phi_b | Relative rotation angle of revolute joint at frame_b | |
| SI.AngularVelocity | w_b | First derivative of angle phi_b (relative angular velocity b) | |
| SI.AngularAcceleration | a_b | Second derivative of angle phi_b (relative angular acceleration b) | |
| SI.Power | totalPower | Total power flowing into this element, if checkTotalPower=true (otherwise dummy) | |
| Modelica.Mechanics.MultiBody.Joints.Revolute | actuatedRevolute_a | ||
| Modelica.Mechanics.MultiBody.Joints.Revolute | actuatedRevolute_b | ||
| Modelica.Mechanics.Rotational.Components.IdealGear | idealGear | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation1 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation2 |