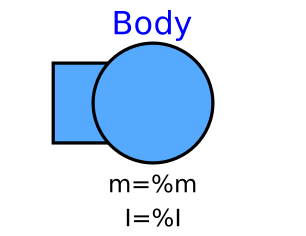
modelBody
Body component with mass and inertia
Information
Model Body is an ideal unlimited small point with mass and inertia.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animate | true | = true, if animation shall be enabled |
| SI.Mass | m | Mass of the body | |
| SI.Inertia | I | Inertia of the body with respect to the origin of frame_a along the z-axis of frame_a | |
| Boolean | enableGravity | true | = true, if gravity effects should be taken into account |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use phi, w and a as states |
| Animation › if animation = true | |||
| SI.Length | zPosition | planarWorld.defaultZPosition | Position z of the body |
| SI.Diameter | sphereDiameter | planarWorld.defaultBodyDiameter | Diameter of sphere |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| PlanarWorld | planarWorld | planar world model | |
| MB.Types.Color | sphereColor | Types.Defaults.BodyColor | Color of sphere |
| MB.Types.SpecularCoefficient | specularCoefficient | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Force[2] | f | Force | |
| SI.Position[2] | r | Translational position | |
| SI.Velocity[2] | v | Velocity | |
| SI.Acceleration[2] | a | Acceleration | |
| SI.Angle | phi | Angle | |
| SI.AngularVelocity | w | Angular velocity | |
| SI.AngularAcceleration | z | Angular acceleration | |
| MB.Visualizers.Advanced.Shape | sphere |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control