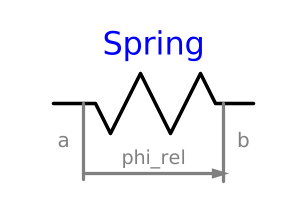
modelSpring
Linear 2D translational spring
Extends from BaseClasses.TwoConnectorShapes (Partial base class containing two frames and cylinder shapes at these frames).
Information
A linear translational spring. x- and y direction stiffness can be parameterized.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.TranslationalSpringConstant | c_x | Spring constant in x dir | |
| SI.TranslationalSpringConstant | c_y | Spring constant in y dir | |
| SI.RotationalSpringConstant | c_phi | Spring constant | |
| SI.Position | s_relx0 | 0 | Unstretched spring length |
| SI.Position | s_rely0 | 0 | Unstretched spring length |
| SI.Angle | phi_rel0 | 0 | Unstretched spring angle |
| Animation | |||
| Boolean | animate (from TwoConnectorShapes) | true | Enable animation |
| Animation › if animation = true | |||
| SI.Length | zPosition (from TwoConnectorShapes) | planarWorld.defaultZPosition | Position z of cylinder representing the fixed translation |
| Animation › Connectors (if animation = true) | |||
| Boolean | animateConnectors (from TwoConnectorShapes) | true | =true, if connectors a and b should be animated as cylinders |
| SI.Diameter | diameterConnector_a (from TwoConnectorShapes) | planarWorld.defaultJointWidth | Diameter of connector at frame_a |
| SI.Diameter | diameterConnector_b (from TwoConnectorShapes) | planarWorld.defaultJointWidth | Diameter of connector at frame_b |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use phi and w as states |
| SI.Position | s_small | 1.E-10 | Prevent zero-division if distance between frame_a and frame_b is zero |
| Boolean | enableAssert | true | Cause an assert when the distance between frame_a and frame_b < s_small |
| Animation › Spring coil (if animation = true) | |||
| Integer | numberOfWindings | 5 | Number of spring windings |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Frame_a | frame_a (from PartialTwoFrames) | Coordinate system fixed to the component with one cut-force and cut-torque | |
| Frame_b | frame_b (from PartialTwoFrames) | Coordinate system fixed to the component with one cut-force and cut-torque |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| MB.Types.SpecularCoefficient | specularCoefficient (from TwoConnectorShapes) | planarWorld.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| MB.Types.Color | colorConnector_a (from TwoConnectorShapes) | Types.Defaults.RodColor | Color of connector at frame_a |
| MB.Types.Color | colorConnector_b (from TwoConnectorShapes) | Types.Defaults.RodColor | Color of connector at frame_a |
| SI.Position | s_relx | Spring length | |
| SI.Position | s_rely | Spring length | |
| SI.Angle | phi_rel | Spring angle | |
| SI.Force | f_x | Force in x direction | |
| SI.Force | f_y | Force in y direction | |
| SI.Length | width | planarWorld.defaultJointWidth | Width of spring |
| SI.Length | coilWidth | width/10 | Width of spring coil |
| MB.Types.Color | color | Types.Defaults.SpringColor | Color of spring |
| SI.Length | length | Distance between the origin of frame_a and the origin of frame_b | |
| SI.Position[3] | r_rel_0 | Position vector (3D) from frame_a to frame_b resolved in multibody world frame | |
| Real[3] | e_rel_0 | Unit vector (3D) in direction from frame_a to frame_b, resolved in multibody world frame |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control