modelDoublePendulum
Simple double pendulum with two revolute joints and two bodies
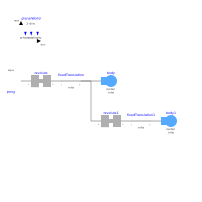
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Beware this is a chaotic system. However, the chaotic part should start after 10s.
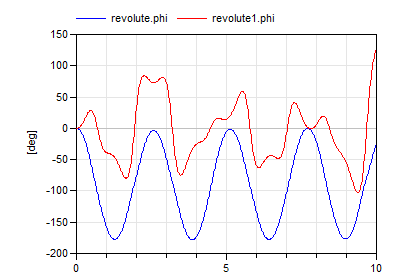
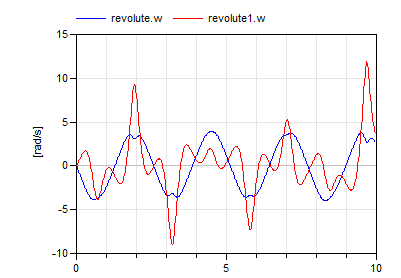
Selected continuous time states
- revolute.phi
- revolute.w
- revolute1.phi
- revolute1.w
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Parts.Body | body | ||
| Parts.FixedTranslation | fixedTranslation | ||
| Parts.Fixed | fixed | ||
| Parts.Body | body1 | ||
| Parts.FixedTranslation | fixedTranslation1 | ||
| PlanarWorld | planarWorld | ||
| Joints.Revolute | revolute | ||
| Joints.Revolute | revolute1 |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control