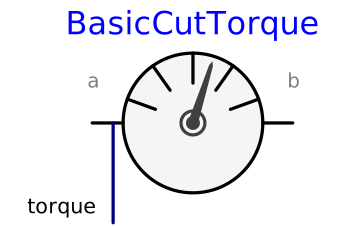
modelBasicCutTorque
Measure cut-torque vector
Extends from Internal.PartialCutTorqueBaseSensor (Base model to measure the cut force and/or torque between two frames, defined by equations (frame_resolve must be connected exactly once)).
Information
This sensor outputs cut-torque between the two connecting frames, whereby the output signal torque = frame_a.t. If parameter positiveSign = false, the negative cut-torque is provided (= frame_b.t).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | positiveSign | true | = true, if torque with positive sign is returned (= frame_a.t), otherwise with negative sign (= frame_b.t) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialCutTorqueBaseSensor) | Coordinate system a | |
| Interfaces.Frame_b | frame_b (from PartialCutTorqueBaseSensor) | Coordinate system b | |
| Modelica.Blocks.Interfaces.RealOutput | torque | Cut torque resolved in frame defined by resolveInFrame |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control