modelRRPositionControl3
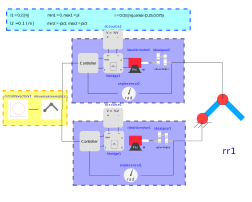
Extends from Modelica.Icons.Example (Icon for runnable examples), Servomechanisms.Examples.RRServomechanism.Data (RR Servomechanism Data).
Information
General
In this model the trayectory trackintg for RR servomechanisms is tested using a real H bridge.
Limitations
The simulations takes a lot of time to complete.Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | l1 (from Data) | 0.2 | |
| Real | w1 (from Data) | 0.02 | |
| Real | h1 (from Data) | 0.005 | |
| Real | d1 (from Data) | 400 | |
| Real | min1 (from Data) | 0 | |
| Real | max1 (from Data) | pi/2 | |
| Real | l2 (from Data) | 0.1 | |
| Real | w2 (from Data) | 0.02 | |
| Real | h2 (from Data) | 0.005 | |
| Real | d2 (from Data) | 400 | |
| Real | min2 (from Data) | -pi/2 | |
| Real | max2 (from Data) | pi/2 | |
| Real | r (from Data) | 0.03 | |
| Real | xc (from Data) | 0.25 | |
| Real | yc (from Data) | 0.075 | |
| Real | ratio1 (from Data) | 10 | |
| Real | ratio2 (from Data) | 5 | |
| Real | period (from Data) | 8 | |
| Real | R (from Data) | 0.101 | |
| Real | L (from Data) | 0.0000266 | |
| Real | k (from Data) | 0.0115 | |
| Real | J (from Data) | 0.0000119 | |
| Real | Voltage (from Data) | 12 | |
| Real | kp2 (from Data) | 4.423 | |
| Real | kp1 (from Data) | 7.1543 |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Sensors.AngleSensor | anglesensor2 | ||
| Modelica.Mechanics.Rotational.Components.IdealGear | idealgear2 | ||
| Modelica.Mechanics.Rotational.Components.IdealGear | idealgear1 | ||
| Modelica.Mechanics.Rotational.Sensors.AngleSensor | anglesensor1 | ||
| Servomechanisms.Control.RRInverseKinematics | rrinversekinematics1 | ||
| Servomechanisms.Control.CircleTrayectory | circletrayectory1 | ||
| Servomechanisms.Mechanism.RR | rr1 | ||
| Servomechanisms.Electrical.IdealDCMotor | idealdcmotor1 | ||
| Servomechanisms.Electrical.DCSource | dcsource1 | ||
| Servomechanisms.Electrical.DCSource | dcsource2 | ||
| Servomechanisms.Control.Controller | controller1 | ||
| Servomechanisms.Control.Controller | controller2 | ||
| Servomechanisms.Electrical.IdealDCMotor | idealdcmotor2 | ||
| Servomechanisms.Electrical.HBridge | hbridge1 | ||
| Servomechanisms.Electrical.HBridge | hbridge2 |