modelInvertedCraneCrab
An inverted model of a pendulum
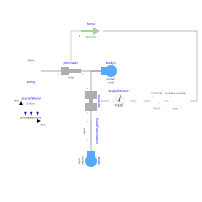
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
The trajectory is stipulated, the force is being measured.
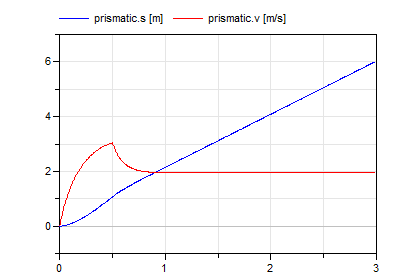
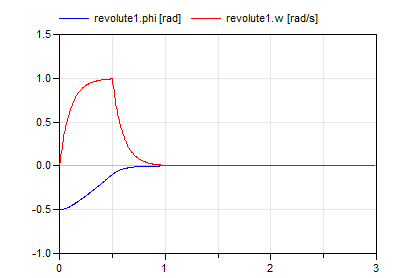
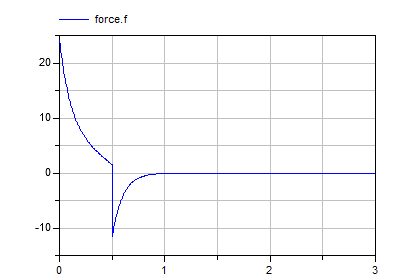
Selected continuous time states
- prismatic.s
- prismatic.v
- revolute.phi
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Parts.Body | body | ||
| Parts.FixedTranslation | fixedTranslation | ||
| Parts.Fixed | fixed | ||
| Parts.Body | body1 | ||
| Modelica.Mechanics.Translational.Sources.Force | force | ||
| Modelica.Mechanics.Rotational.Sensors.AngleSensor | angleSensor | ||
| Modelica.Blocks.Math.InverseBlockConstraints | inverseBlockConstraints | ||
| Modelica.Blocks.Sources.Ramp | ramp | ||
| Modelica.Blocks.Continuous.FirstOrder | firstOrder | ||
| PlanarWorld | planarWorld | ||
| Joints.Revolute | revolute | ||
| Joints.Prismatic | prismatic |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control