
modelPowerDistanceDemo
Power and distance sensor demo
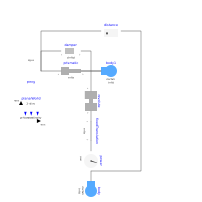
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
This example shows how to use sensors for power and distance. The crane crab is used as an example.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Parts.Body | body | ||
| Parts.FixedTranslation | fixedTranslation | ||
| Parts.Fixed | fixed | ||
| Parts.Body | body1 | ||
| PlanarWorld | planarWorld | ||
| Parts.Damper | damper | ||
| Joints.Revolute | revolute | ||
| Joints.Prismatic | prismatic | ||
| Sensors.Power | power | ||
| Sensors.Distance | distance |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control