modelMinimalChassis3
Basic chassis model with rigid connection between all 4 wheels, uses chassisFrame connection, includes wheel bearings
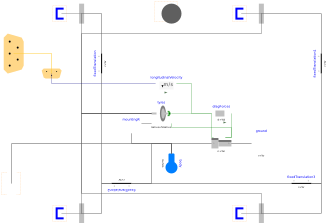
Extends from MinimalChassis2 (Basic chassis model with rigid connection between all 4 wheels, uses chassisFrame connection).
Information
Single degree-of-freedom chassis model with mass and speed dependant drag model. Uses MultiBody wheelHub connections and positions these relative to the vehicle body position.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Mass | vehicleMass (from MinimalChassis2) | 1200 | Vehicle mass |
| SI.Radius | tyreRadius (from MinimalChassis2) | 0.34 | Tyre rolling radius |
| SI.TranslationalDampingConstant | drag (from MinimalChassis2) | 1 | Drag force (force = drag*vehicle_speed) |
| Advanced › Only for 1D chassis | |||
| Boolean | usingMultiBodyDriveline (from Base) | false | = true, if connecting to a MultiBody driveline |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | chassisFrame (from Base) | Chassis reference frame (optional) | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | steeringWheel (from Base) | Steering wheel connection (optional) | |
| VehicleInterfaces.Interfaces.ControlBus | controlBus (from Base) | Control signal bus | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_1 (from TwoAxleBase) | Front left wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_2 (from TwoAxleBase) | Front right wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_3 (from TwoAxleBase) | Rear left wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_4 (from TwoAxleBase) | Rear right wheel |