
modelMeasureDemo
Measure demo
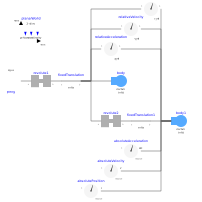
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
This example shows how to use absolute and relative sensors for position, velocity and acceleration. For demonstration purposes a double pendulum is used.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Parts.Body | body | ||
| Parts.FixedTranslation | fixedTranslation | ||
| Parts.Fixed | fixed | ||
| Parts.Body | body1 | ||
| Parts.FixedTranslation | fixedTranslation1 | ||
| PlanarWorld | planarWorld | ||
| Sensors.AbsolutePosition | absolutePosition | ||
| Sensors.RelativePosition | relativePosition | ||
| Joints.Revolute | revolute1 | ||
| Sensors.AbsoluteVelocity | absoluteVelocity | ||
| Sensors.RelativeVelocity | relativeVelocity | ||
| Sensors.AbsoluteAcceleration | absoluteAcceleration | ||
| Sensors.RelativeAcceleration | relativeAcceleration | ||
| Joints.Revolute | revolute2 |
Revisions
 Developed 2010 at the DLR Institute of System Dynamics and Control